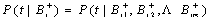|
|
|
| DD at a point is a measure of how many instances
from different bags are |
||
| near that point and how far away the negative instances are. |
||
| The algorithm returns point(s) in feature space with
high DD |
||
|
|
|
|
| • | For a
single point target concept (t) and positive and negative bags (B), we |
||
| can
find t by maximizing |
|||
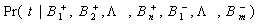
|
|
|
|
| • | If we
assume a uniform prior, and that bags are conditionally independent |
||
| given
the concept, then we maximize likelihood |
|||
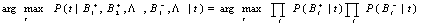
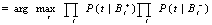
|
|
|
| • | Each
bag is made up of many instances |
|